Choose a hollow-shaft encoder system or a magnetic target
OME series
Start with the OME model table for bore, outside diameter, resolution, accuracy and controller interface. Review each model before choosing its mounting arrangement.
OMEC series
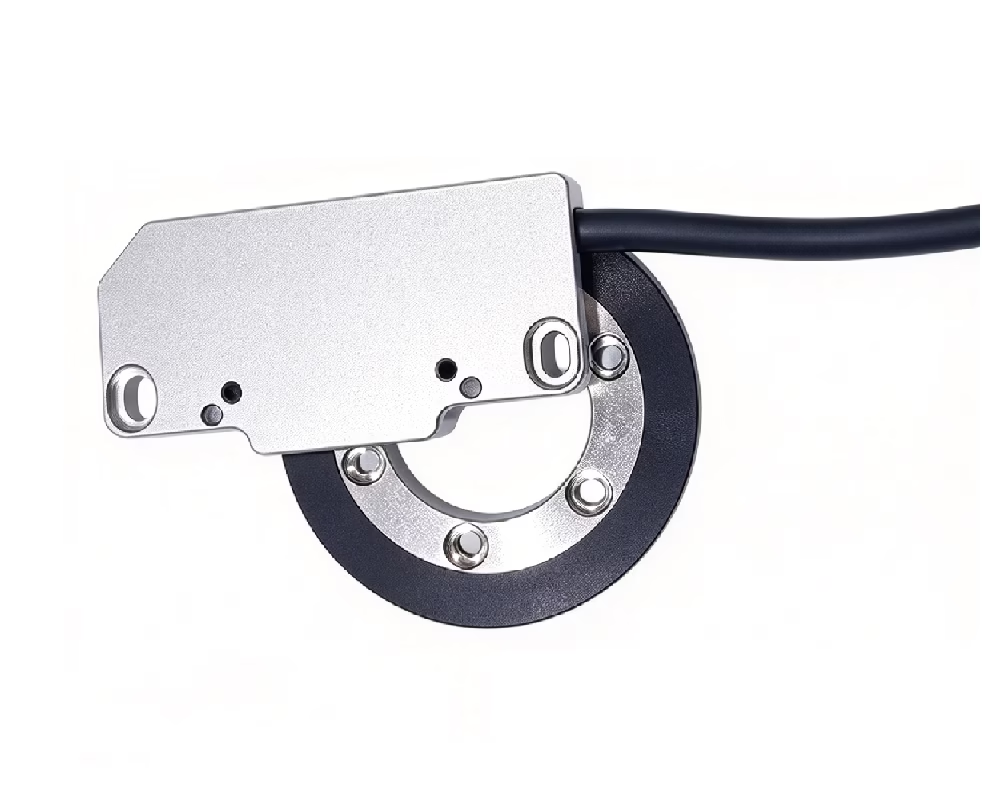
OTV-OMEC hollow-shaft absolute rotary encoders provide a thin-profile option with IP67-rated configurations. Check the selected assembly, connector and installation conditions.
Magnetic target only
Magnetic encoder rings and discs are intended for designs with their own readhead electronics. Select the IC, track geometry and mechanical carrier together.
Before release, verify runout, operating gap, signal quality, calibration and position repeatability after power cycling. Follow the hollow-shaft encoder assembly and calibration guide.
What Is an Off-Axis Magnetic Encoder?
An off-axis magnetic encoder is a rotary position sensor where the sensing element (Hall or MR chip) is positioned beside the rotating shaft rather than at its end. A diametrically magnetized ring or multi-pole magnet ring is mounted on the shaft, and the sensor reads the rotating magnetic field from the side — hence “off-axis.”
A hollow-shaft magnetic encoder takes this a step further: the magnet ring has a large center bore, allowing cables, shafts, or fluid lines to pass through the encoder. This enables true zero-backlash, bearingless integration into robot joints, servo motors, and medical equipment.
On-Axis
Sensor sits at the end of the shaft. Requires the shaft end to be accessible. Occupies axial space.
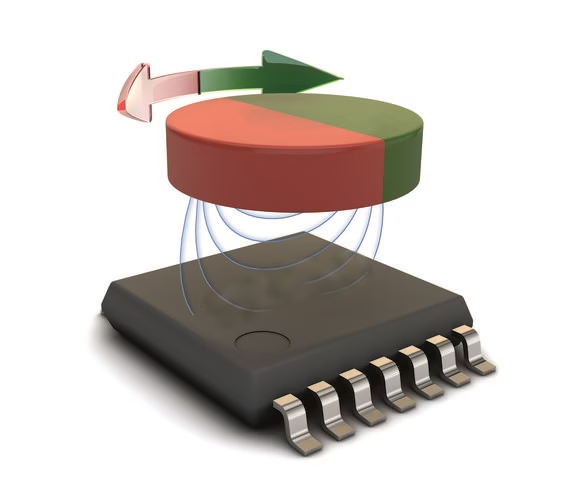
Off-Axis (Hollow-Shaft)
Sensor reads the magnet ring from the side. Shaft passes through the ring. Saves axial space.
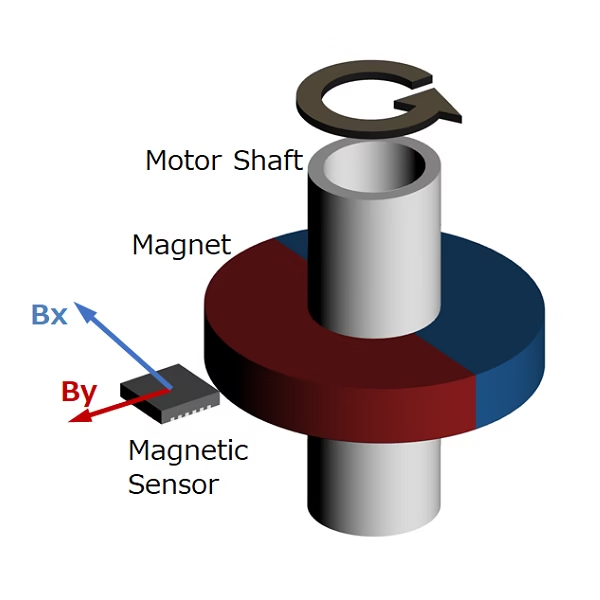
How Magnetic Encoders Work
Magnet Ring Creates a Rotating Field
A multi-pole or diametrically magnetized ring is mounted on the rotating shaft. As the shaft turns, the magnetic field pattern rotates in sync. Key parameters: pole pair count, magnetic flux density, pole width uniformity.
Sensor Chip Detects Field Orientation
A magnetic encoder IC (Hall-effect or MR-based) placed adjacent to the ring measures the in-plane magnetic field components. The IC computes the instantaneous field angle using internal arctangent calculation.
Digital Output to Controller
The IC outputs absolute or incremental angle data via standard protocols — SSi, BiSS-C, SPI, ABZ, or UART — directly to the motor drive, robot controller, or PLC.
The advantages of off-axis magnetic sensing over optical encoders are decisive for industrial applications: no glass disc to crack, no LED to dim, no optical path to contaminate. The non-contact magnetic principle is inherently immune to dust, oil, condensation, and vibration.
Mainstream Magnetic Encoder Chips
The off-axis magnetic encoder ecosystem is built around dedicated encoder ICs. Each chip family has specific requirements for the magnet ring — pole count, field strength, geometry — that directly affect achievable resolution and accuracy.
| Manufacturer | Key IC Series | Type | Resolution | Interface | OTV Ring Compatible |
|---|---|---|---|---|---|
| iC-Haus | iC-MU200, iC-MU150, iC-PVL | Hall Array | 18-22 bit | BiSS-C, SSi, SPI, ABZ | ✓ Yes |
| RLS (Renishaw) | Orbis, AksIM, LinACE | Hall Array | 14-20 bit | BiSS-C, SSi, SPI | ✓ Yes |
| AMS (Osram) | AS504x, AS5147, AS5600 | Hall Array | 12-14 bit | SPI, I2C, ABZ, PWM | ✓ Yes |
Additional encoder ICs from Melexis, Infineon, AKM, and others are also supported. View the full encoder IC compatibility guide →
Each IC has a defined magnetic input specification: the field strength range at the sensor location, typically 20–80 mT. The magnet ring must deliver the correct field amplitude at the air gap distance between ring surface and sensor. OTV designs magnet rings to match each chip’s optimal operating window. See: Magnetic Target for iC-Haus IC-MU200.
OTV Standard Off-Axis Magnetic Encoder — OME Series
The OME Series is OTV’s standard off-axis magnetic encoder product line. Each model features a hollow-shaft, bearingless design with a separated stator-rotor structure, with major encoder ICs listed above.
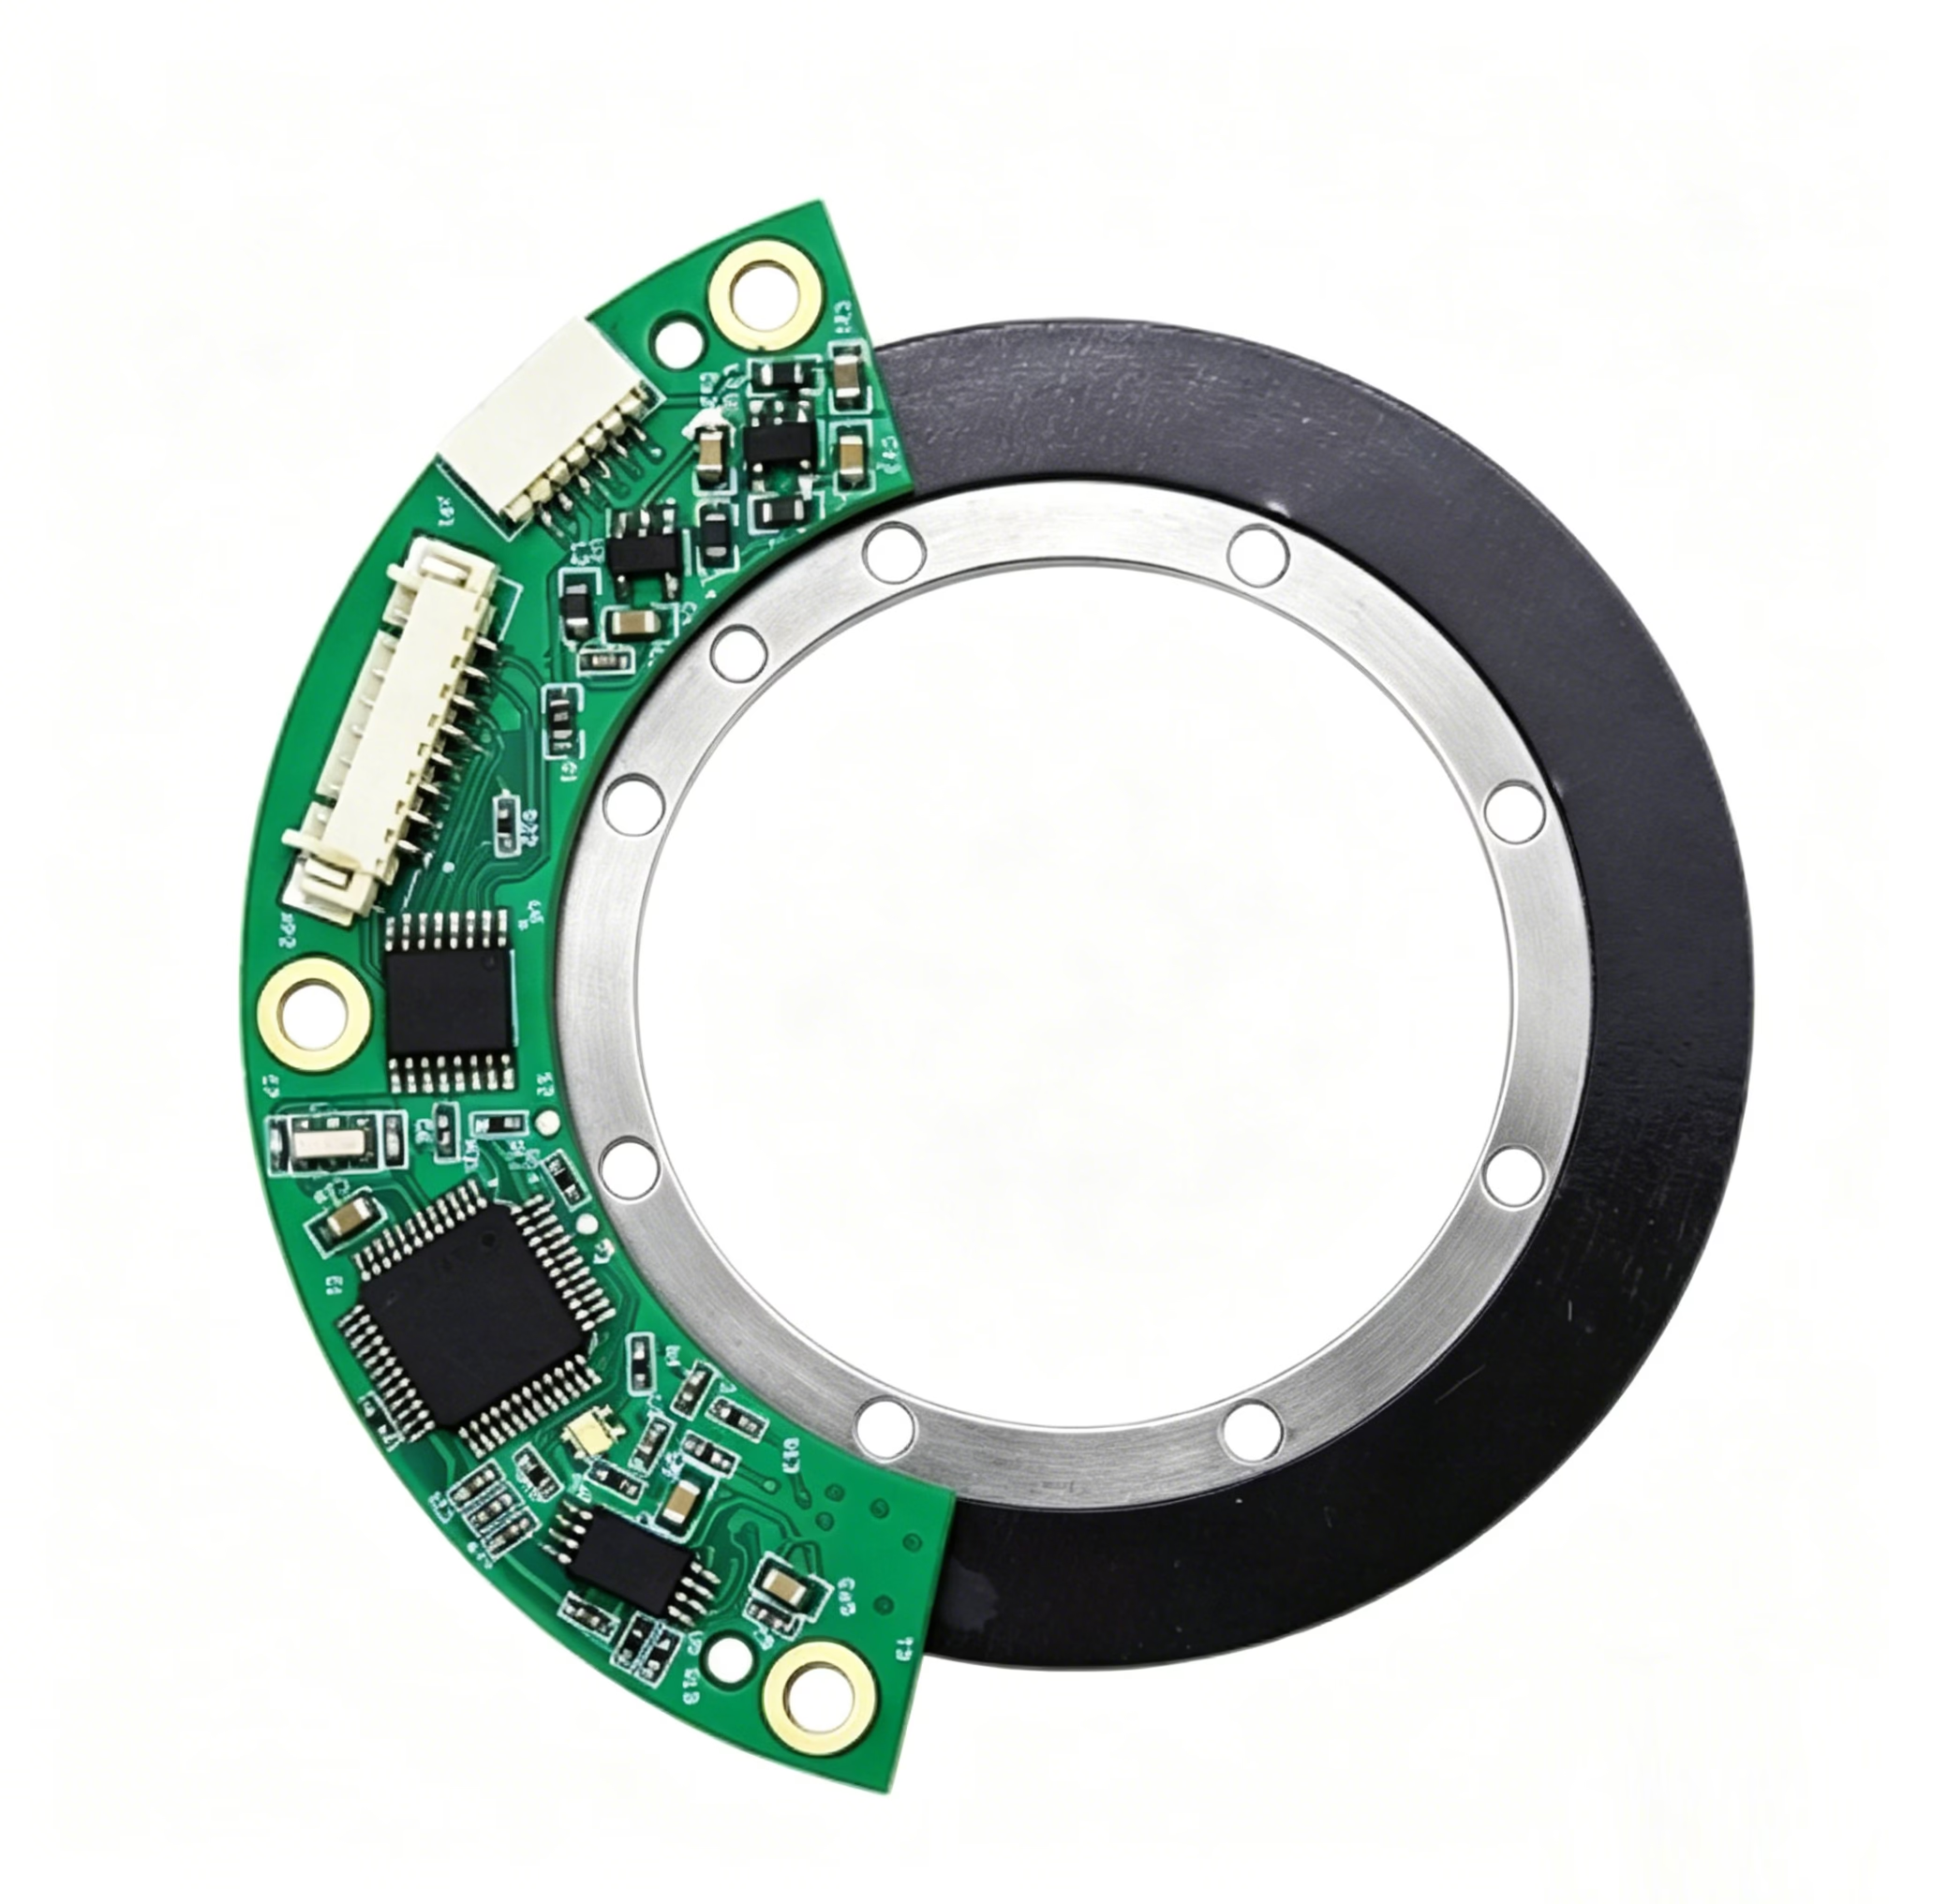
OTV OME Series — Off-Axis Hollow-Shaft Magnetic Encoder
| 1. Basic Performance | |||||||||
|---|---|---|---|---|---|---|---|---|---|
| Parameter | OME06 | OME08 | OME10 | OME15 | OME20 | OME25 | OME35 | OME45 | OME65 |
| Product |  | |  | 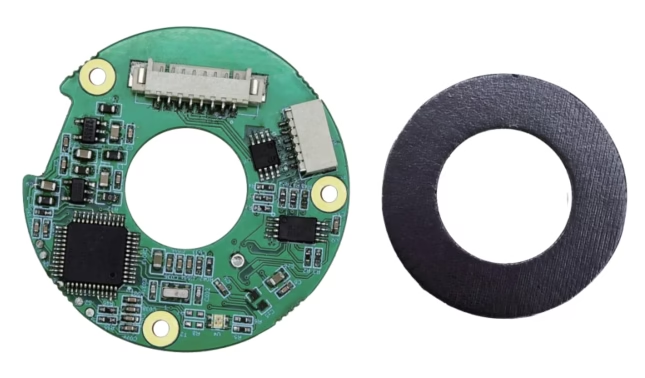 |  | 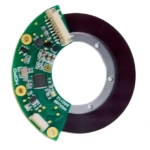 | 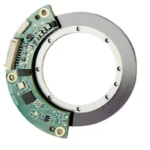 | 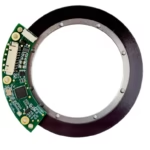 | 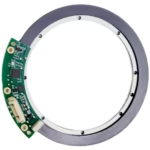 |
| Resolution | 17 bit | 18 bit | 17-18 bit | 17-18 bit | 17-19 bit | 17-19 bit | 17-20 bit | 17-20 bit | 17-20 bit |
| Max Static Error | ±0.1° | ±0.1° | ±0.1° | ±0.1° | ±0.1° | ±0.1° | ±0.1° | ±0.1° | ±0.1° |
| Repeatability | ±1 LSB | ±1 LSB | ±1 LSB | ±1 LSB | ±1 LSB | ±1 LSB | ±1 LSB | ±1 LSB | ±1 LSB |
| Max Speed | 6,000 rpm | 6,000 rpm | 6,000 rpm | 6,000 rpm | 6,000 rpm | 6,000 rpm | 5,000 rpm | 5,000 rpm | 5,000 rpm |
| Range | Single Turn Absolute / Muti Turn Absolute Optional | ||||||||
| Direction | CW Incrementing (Configurable) | ||||||||
| 2. Mechanical Dimensions & Mounting | |||||||||
|---|---|---|---|---|---|---|---|---|---|
| Parameter | OME06 | OME08 | OME10 | OME15 | OME20 | OME25 | OME35 | OME45 | OME65 |
| Target Ring OD/ID/T (mm) | 22/6/2 | 22/10/2 | 29/10/2 | 29/15/2 | 39/20/2 | 49/25/2 | 55/35/2.5 | 64/45/2.5 | 84/65/2.5 |
| Readhead OD/ID/T (mm) Angle (°) | 28.5/8.5/4.15 360 | 32/8/6.1 360 | 38/14/3.85 360 | 38/18/3.85 360 | 54/21.2/5.8 196 | 59/26/6.42 138 | 67/42/6.1 150 | 75/51/6.1 90 | 96/70/6.1 77 |
| Weight (approx.) | 8 g | 9g | 11 g | 13g | 15 g | 18 g | 22 g | 25 g | 30 g |
| Eccentricity | ±0.1 mm | ||||||||
| Air Gap (Chip surface to Target Ring) | 0.5±0.1mm | 0.5±0.1mm | 0.5±0.1mm | 0.5±0.1mm | 1.3±0.1mm | 0.5±0.1mm | 0.5±0.1mm | 0.5±0.1mm | 0.5±0.1mm |
| Inertia (kg·mm²) | 0.29 | 0.32 | 0.69 | 0.78 | 2.58 | 5.45 | 10.63 | 18.88 | 46.48 |
| 3. Environmental Conditions | |
|---|---|
| Operating Temperature | -30°C to +85°C |
| EMC Standards | IEC 61000-6-2, IEC 61000-6-4 |
| Relative Humidity | 0-99% (non-condensing) |
| Shock Resistance | 100 g / 11 ms |
| Vibration | 0.04 g²/Hz (10 Hz – 2,000 Hz) |
| 4. Electrical & Interface | |
|---|---|
| Supply Voltage | 5 V ±5% |
| Current | ≤100 mA |
| Electrical Connector | 8-Pin Connector |
| Output Protocols | SSi, BiSS-C,SPI, ABZ |
Download Product Datasheets
PDF datasheet with full mechanical drawings, electrical specs, and ordering codes
All models: Single-turn/Muti-turn absolute · Non-contact · Separated stator-rotor · FR-4 material · Additional sizes and custom configurations available on request. The product includes mounting bolts, a 10 cm wire harness with connector.
OTV Sensing · Hollow-Shaft Absolute Encoder
OTV-OMEC Series – Thin-Profile IP67 Encoders
For rotary stages, robot joints, and compact actuators that need an open center bore, the OTV-OMEC is a non-contact, off-axis absolute rotary encoder with a slim ring assembly. Single-turn position is available at power-up, with bore sizes from 25 mm to 65 mm.
The ring uses an axial magnetization pattern. Resolution, speed, mounting pattern, and thickness vary by configuration; the IP67 rating applies to the specified encoder system and should be confirmed for the final installation.
OTV-OMEC model selection by bore
Compare the bore first, then check ring outside diameter, mounting holes, and axial space. The two ID25 mounting options are listed separately because their hole patterns and thickness differ.
| OTV model | Bore / ID | Ring OD | Resolution | Max. speed* | Mounting holes | Thickness |
|---|---|---|---|---|---|---|
| OTV-OMEC-ID25 · 4-hole | 25 mm | 49 mm | 16-20 bit | Up to 9,500 rpm | 4 | 2.0 mm |
| OTV-OMEC-ID25 · 6-hole | 25 mm | 49 mm | 16-20 bit | Up to 9,500 rpm | 6 | 3.9 mm |
| OTV-OMEC-ID31.5 | 31.5 mm | 49 mm | 16-20 bit | Up to 9,500 rpm | 0 | 2.0 mm |
| OTV-OMEC-ID62 | 62 mm | 84 mm | 16-20 bit | Up to 4,700 rpm | 0 | 1.8 mm |
| OTV-OMEC-ID65 | 65 mm | 84 mm | 16-20 bit | Up to 4,700 rpm | 8 | 2.5 mm |
* Maximum speed depends on ring size and operating conditions. Confirm the rating for the final assembly.
Electrical and environmental data
5 V +/- 5% supply; <85 mA no-load current at 25 °C; <100 ms startup; -30 °C to +85 °C; +/-0.5 mT external magnetic field during operation.
Interfaces and connection
BiSS-C, SSI, SPI, or Tamagawa, depending on configuration. Connector options include DB9, DB15, 8-pin M12, or bare wire. Confirm protocol, pinout, and cable requirements for the controller.
System accuracy and IP protection depend on the selected configuration and installation. Check alignment, air gap, ring runout, sealing, and controller interface before design release.
Where Off-Axis Magnetic Encoders Excel


Medical Devices
CT gantry rotation, surgical robots, prosthetic joints. Sterile-compatible, non-contact.

AGV & Mobile Robots
Steering angle feedback immune to drive motor magnetic interference.

Aerospace Actuators
Flight control surfaces, landing gear. Wide temperature, vibration resistant.

Oil & Gas Equipment
Downhole tool positioning. High-temperature magnets up to 250°C.
Why OTV for Off-Axis Magnetic Encoder Solutions
① Magnet Ring & Encoder from ONE Supplier
We manufacture both the precision magnet ring and the encoder module. No finger-pointing between magnet supplier and sensor integrator — one partner, one guarantee.
② In-House Precision Magnetization
Custom-built magnetization fixtures, closed-loop current control, 100% pole-width inspection. Custom rings shipped in 2 weeks.
③ Full Encoder IC Compatibility
Magnet rings characterized for iC-Haus, RLS, AMS encoder ICs. Field strength, air gap, and pole geometry matched to each chip’s optimal operating point.
④ Direct Replacement for RLS & Competitors
Form-fit-function compatible magnet rings for RLS magnetic encoders. Customization possible at no NRE for qualified projects.
Need an Off-Axis Magnetic Encoder Solution?
Tell us your encoder IC, pole count, ID/OD, and accuracy target. We’ll recommend the optimal OME series encoder or magnet ring — or design one from scratch.
Standard samples in 1 week. Custom rings in 2–4 weeks. Engineering support included.
Contact OTV Engineering Team →
thomas@otvsensing.com
OTV Precision Sensing | www.otvsensing.com | Suzhou, China