Magnetic Rings & Encoder Discs / Custom Engineering
Custom Magnetic Encoder Rings
Specify a magnetic target around your encoder IC and mechanical installation. OTV Sensing develops custom ring and disc geometry, magnetization patterns and carrier options for rotary position feedback.
Start with the sensor
Send the exact IC or readhead, scan diameter, number of pole pairs and axial or radial sensing arrangement.
Define the installation
Provide bore, outside diameter, thickness, mounting features, nominal air gap and runout limits.
Validate the assembly
Evaluate field strength, signal quality, calibration, temperature and power-cycle repeatability with the selected electronics.
Need an existing size? Compare standard magnetic encoder rings and discs. For scan-diameter calculations, use the iC-MU magnetic ring design guide.
Custom samples: 2 weeks. Volume production: 4 weeks. Confirm the drawing and project schedule with OTV Sensing. Discuss your custom magnetic target.
What is a magnetic encoder ring?
An encoder converts mechanical movement—angular position, linear position or speed—into electrical signals. Encoder systems are used in industrial automation, robotics, motor control and medical devices.
Encoders can be classified based on their working principles:
| Encoder Type | Working Principle | Key Characteristics |
|---|---|---|
| Optical Encoder | Uses a grating and photoelectric sensor to detect light signal changes | High resolution, high precision, sensitive to contamination |
| Magnetic Encoder | Uses a magnetic ring’s field variation, detected by a magnetic sensor | Contamination-resistant, non-contact, high reliability |
| Inductive Encoder | Detects position change based on electromagnetic induction | Strong interference immunity, no magnetic materials needed |
Application conditions at a glance
You should consider a magnetic encoder in the following scenarios:
| Application Scenario | System Conditions / Requirements | Why a Magnetic Encoder Fits | Typical Industry Use |
|---|---|---|---|
| Harsh Environments | Dust, oil, moisture, condensation | No optical path, unaffected by contamination | Industrial Automation, Heavy Machinery |
| Space-Constrained | Limited axial or radial space | Compact ring structure, easy integration | Compact Motors, Robot Joints |
| High Reliability Needs | Long continuous operation, difficult maintenance | Non-contact, no wear, long lifespan | Industrial Equipment, AGV/AMR |
| Larger Mechanical Tolerances | Eccentricity, runout, installation error | High tolerance to mechanical errors | Mass-Produced Equipment, Complex Assemblies |
| Customization Required | Non-standard structure, special pole count | Ring and magnetization can be customized | Custom Motors, Special Actuators |
| High Consistency Needs | Mass production, stable output | Controllable magnetic field, good consistency | Industrial Robots, Automated Lines |
A magnetic encoder typically consists of: a PCBA with the magnetic encoder chip at its core + the magnetic encoder ring + the mechanical housing.
Magnetic encoder chips can be categorized by principle: Hall, AMR, TMR, etc.
Selection criteria by operating condition
You should consider a magnetic encoder in the following scenarios:
| Application Scenario | System Conditions / Requirements | Why Magnetic Encoder Fits | Typical Industry Use Cases |
|---|---|---|---|
| Harsh Environments | Dust, oil, moisture, condensation | No optical path, resistant to contamination, high stability | Construction machinery positioning, motor feedback in food production lines |
| Space-Constrained | Limited axial/radial installation space | Thin-ring design, can be embedded into compact structures, high integration | Robotic joint motors, UAV gimbal motors |
| High-Reliability Needs | Long continuous operation, minimal maintenance windows | Non-contact, no wear, lifespan >100,000 hours, maintenance-free | AGVs in automated warehouses, wind turbine pitch systems |
| Wide Tolerance Applications | Installation eccentricity (>0.5mm) or shaft runout | Tolerant to air gap variations, strong magnetic field adaptability | Batch assembly of home appliance motors, industrial pump/valve control |
| Customization Required | Non-standard mounting interfaces, special pole pairs, or index signal needs | Customizable ring size/poles/index position to match mechanical designs | Medical device motors, aerospace actuators |
| High Consistency Needs | Mass production with output signal error <±1% | Consistent magnetization in batch production (deviation <0.3°) | New energy vehicle motors, servo motor mass production |
Magnetic Encoder System Components
▸ Sensing Core: Magnetic Encoder Chip (Hall/AMR/TMR supported)
▸ Magnetic Source: Customized Magnetic Target (material/size/poles configurable)
▸ Integration Carrier: PCBA + Mechanical Housing (adaptable to customer mounting interfaces)
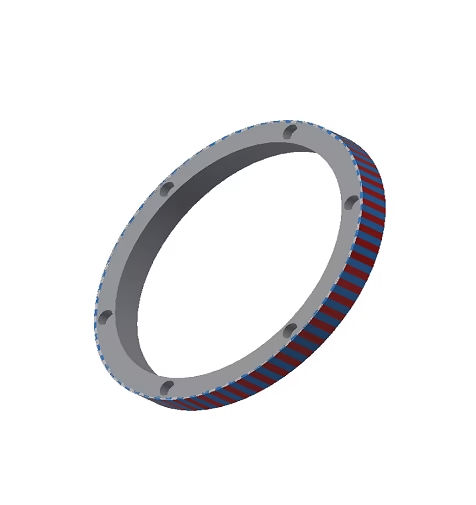
Typical structure of a bonded-rubber magnetic target

When does a magnetic target need to be customized?
In industrial and robotic applications, encoder accuracy and repeatability depend on three elements working together: the sensor IC, the magnetic target and the mechanical installation.
A change to the chip, mounting arrangement or available space can move the design beyond the limits of a standard ring.
Common application constraints include:
- Restricted installation space
- An additional reference mark
- Concentricity and runout tolerances
- High-speed or high-vibration operation
- Special mounting or fastening methods
Custom dimensions, tolerances, mounting features and magnetization patterns allow the target to be designed around these constraints. The resulting system must be validated for the required precision and reliability.
Multipole magnetic targets: choose the track arrangement
A multipole magnetic target has alternating north and south poles around its circumference. Increasing the number of pole pairs can increase spatial subdivision when supported by the sensor and signal processing. The usable resolution and signal quality still depend on the complete system.
Multipole targets are used in industrial servos and robot joints that need continuous angular feedback. Select the number of pole pairs with the chip capability, magnetic geometry, signal stability and cost in mind.
Common track arrangements include:
- Single-track multipole target: a periodic magnetic track for the selected sensing arrangement.
- Single track with a reference mark: an additional reference feature supports homing or indexed position recovery. A reference mark alone does not provide a unique absolute angle immediately after power-up.
- Two-track multipole target: a matched Master/Nonius arrangement can provide absolute position by comparing the phases of the two tracks.

Radially magnetized encoder rings

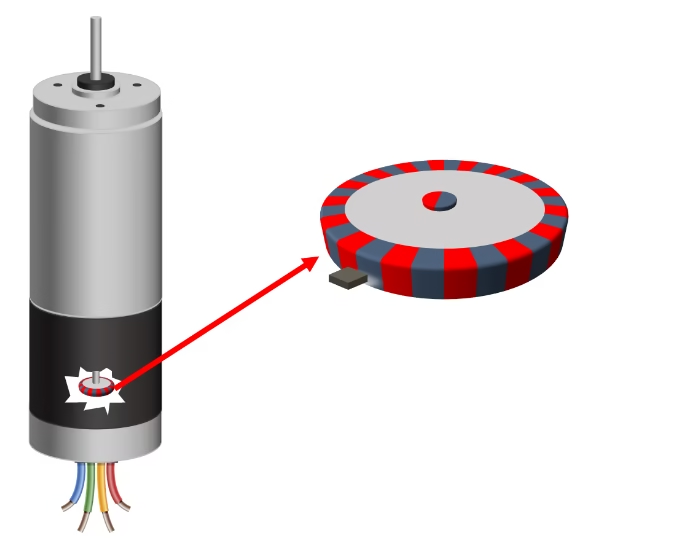
Radial magnetization produces the relevant field at the ring’s inner or outer cylindrical surface. It is a common arrangement for shaft-mounted encoder systems with the sensor positioned beside the circumference.
In industrial motors and robot joints, a suitable radial target and sensor arrangement can improve tolerance to installation variations. Confirm the usable air gap, field symmetry and signal quality over the actual mechanical tolerance range.
Axially magnetized encoder rings
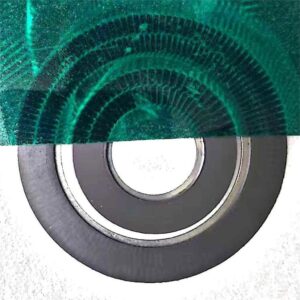
Axial encoder ring for an iC-Haus iC-MU family sensing arrangement
Axial magnetization presents the relevant field at the ring’s end face. It is useful when an end-face sensing arrangement suits the available mounting envelope.
Robot end-effectors, compact servo modules and integrated encoders can use an axially scanned ring to fit position feedback into a limited axial space. Compare the complete installation envelope with the radial alternative.
OTV Sensing offers standard magnetic targets for matched iC-Haus iC-MU, iC-MU150 and iC-MU200 designs. We also develop custom rings around the selected chip and mechanical requirements. Confirm the target drawing, track geometry and installation conditions for the exact device.
Linear magnetic encoder targets

Linear magnetic encoders use a matched readhead and magnetic scale to measure linear displacement and provide feedback for a closed-loop control system.
Two common scale arrangements are:
- Single-track linear magnetic scales
- Dual-track linear magnetic scales
Common specified magnetization pitches include 1 mm, 2 mm and 5 mm. Confirm whether the selected specification refers to a pole width or a complete magnetic period, and match the scale to the chosen readhead.
How bonded-rubber magnetic rings are manufactured
A typical bonded-rubber magnetic ring combines a metal carrier with a rubber compound containing ferrite powder. After the carrier and magnetic material are assembled, pulse magnetization creates the specified pole pattern around the ring.
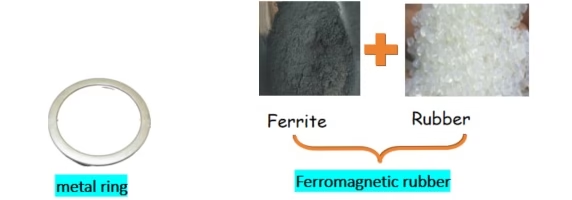
Bonded magnetic rubber combines ferrite powder with an uncured rubber compound, such as nitrile rubber, and is cured through vulcanization. Manufacturing control focuses on uniform powder dispersion and the required ferrite loading within the rubber matrix.

Magnetization uses high-voltage pulse equipment to generate a strong magnetic field and establish the required magnetic orientation in the ferrite-filled rubber.
Magnetization consistency depends on:
- Uniformity of the rubber compound
- Accuracy of the magnetization tooling
- Concentricity of the magnetization and rotation mechanism

Every product is measured before shipment against the agreed magnetic target inspection criteria. Define the required checks and acceptance limits during the engineering review.
Industrial applications for custom magnetic targets
Industrial Servo Motors
Robot Joints and Actuators
Position Feedback for Automated Equipment
Precision Rotary Control Systems


Define your custom magnetic encoder ring
We review the following customization parameters against your magnetic encoder IC and mechanical installation:
- Magnetic pattern: number of pole pairs, pole width and magnetic period
- Sensing direction: radial or axial magnetization
- Special coding: application-specific magnetization patterns
- Reference features: a missing pole or another agreed reference mark
- Magnetic field: strength and distribution at the sensing location
- Mechanical geometry: ring dimensions and tolerances, including thin designs such as 1 mm where the application and manufacturing process allow
If you are developing an industrial or robotic encoder system, send us the magnetic target requirements and the available installation envelope. Our engineers can work with you on the magnetization scheme and mechanical structure.
Custom magnetic encoder ring FAQ
When should you consider using a magnetic encoder?
Consider a magnetic encoder when your application involves dust, oil, moisture, or condensation, or when you have stringent requirements for installation space, mechanical tolerances, or long-term operational reliability. It’s particularly well-suited for industrial automation, robotics, and heavy machinery where compactness and durability are key.
Why might you need a custom magnetic encoder ring instead of a standard one?
Because encoder system performance depends on the combined effect of the ring, sensor chip, and mechanical housing. When installation space, mechanical tolerances, speed, or needed features (like a reference mark) fall outside standard product ranges, a custom ring lets you optimize dimensions, magnetization, and mounting to ensure peak system accuracy, stability, and reliability.
What key parameters can typically be adjusted when customizing a magnetic encoder ring?
Key customizable parameters include: pole-pair count and pitch, magnetization direction (radial/axial), magnetic field strength, precise ring dimensions and tolerances, mechanical mounting interfaces, and special features like the shape and location of a reference mark. These must be matched to your sensor’s characteristics and mechanical design.
What is the typical development and production timeline for a custom magnetic encoder ring?
The project has two stages: sample development—design review, tooling where required, and prototype fabrication—and volume production and delivery after sample approval.
Our confirmed lead times are 2 weeks for custom samples and 4 weeks for volume production. Confirm the project schedule after drawing and order approval. Additional development or new tooling may require a separate schedule, depending on design complexity, magnetization process and order quantity.
Is there a Minimum Order Quantity (MOQ) for custom rings?
We can provide prototype samples based on your actual initial quantity requirements. Please note that the cost for these initial samples will vary accordingly based on the specifications.
What are the key steps in a typical custom development process?
The main steps are:
1. Requirements Communication: Clarify all technical parameters (dimensions, pole count, operating environment, etc.).
2. Design & Confirmation: Provide drawings for mutual confirmation.
3. Sample Fabrication & Testing: Deliver physical samples and test reports.
4. Customer Validation: You test the samples in your system and provide feedback.
5. Batch Production & Delivery: Mass production and shipment according to the confirmed specifications.
Discuss your magnetic target with OTV Sensing
Send the sensor IC or readhead, bore and outside diameter, thickness, number of pole pairs, mounting drawing and operating conditions. We can review a custom target or help identify a suitable standard ring.